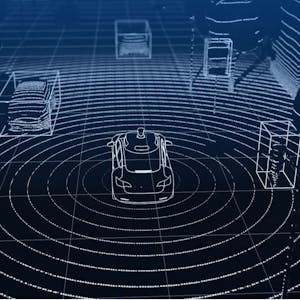
Visual Perception for Self-Driving Cars
About this course
Welcome to Visual Perception for Self-Driving Cars, the third course in University of Toronto’s Self-Driving Cars Specialization. This course will introduce you to the main perception tasks in autonomous driving, static and dynamic object detection, and will survey common computer vision methods for robotic perception. By the end of this course, you will be able to work with the pinhole camera model, perform intrinsic and extrinsic camera calibration, detect, describe and match image features and design your own convolutional neural networks. You'll apply these methods to visual odometry, object detection and tracking, and semantic segmentation for drivable surface estimation. These techniques represent the main building blocks of the perception system for self-driving cars. For the final project in this course, you will develop algorithms that identify bounding boxes for objects in the scene, and define the boundaries of the drivable surface. You'll work with synthetic and real image data, and evaluate your performance on a realistic dataset. This is an advanced course, intended for learners with a background in computer vision and deep learning. To succeed in this course, you should have programming experience in Python 3.0, and familiarity with Linear Algebra (matrices, vectors, matrix multiplication, rank, Eigenvalues and vectors and inverses).
90/100
CourseAsk score
- What the provider tells you
- 39/45
- Who stands behind it
- 35/35
- How complete the listing is
- 16/20
Scores how much the provider publishes and who stands behind it — not how well it is taught.
What you'll learn
- Work with the pinhole camera model
- Perform intrinsic and extrinsic camera calibration
- Detect, describe, and match image features
- Design convolutional neural networks
- Apply perception methods to visual odometry, object detection, and tracking
- Conduct semantic segmentation for drivable surface estimation
Course objectives
- Understand main perception tasks in autonomous driving
- Survey common computer vision methods for robotic perception
- Develop algorithms that identify bounding boxes for objects in a scene
Price shown by Coursera — confirm on their site.
Enroll on CourseraYou'll be redirected to Coursera to complete enrollment.
- Listed & compared by CourseAsk
- English · 0

 Udemy

 Coursera
 edX




Compared on these lists
Where this course ranks against the alternatives.